MBot Classic Wiring Guide
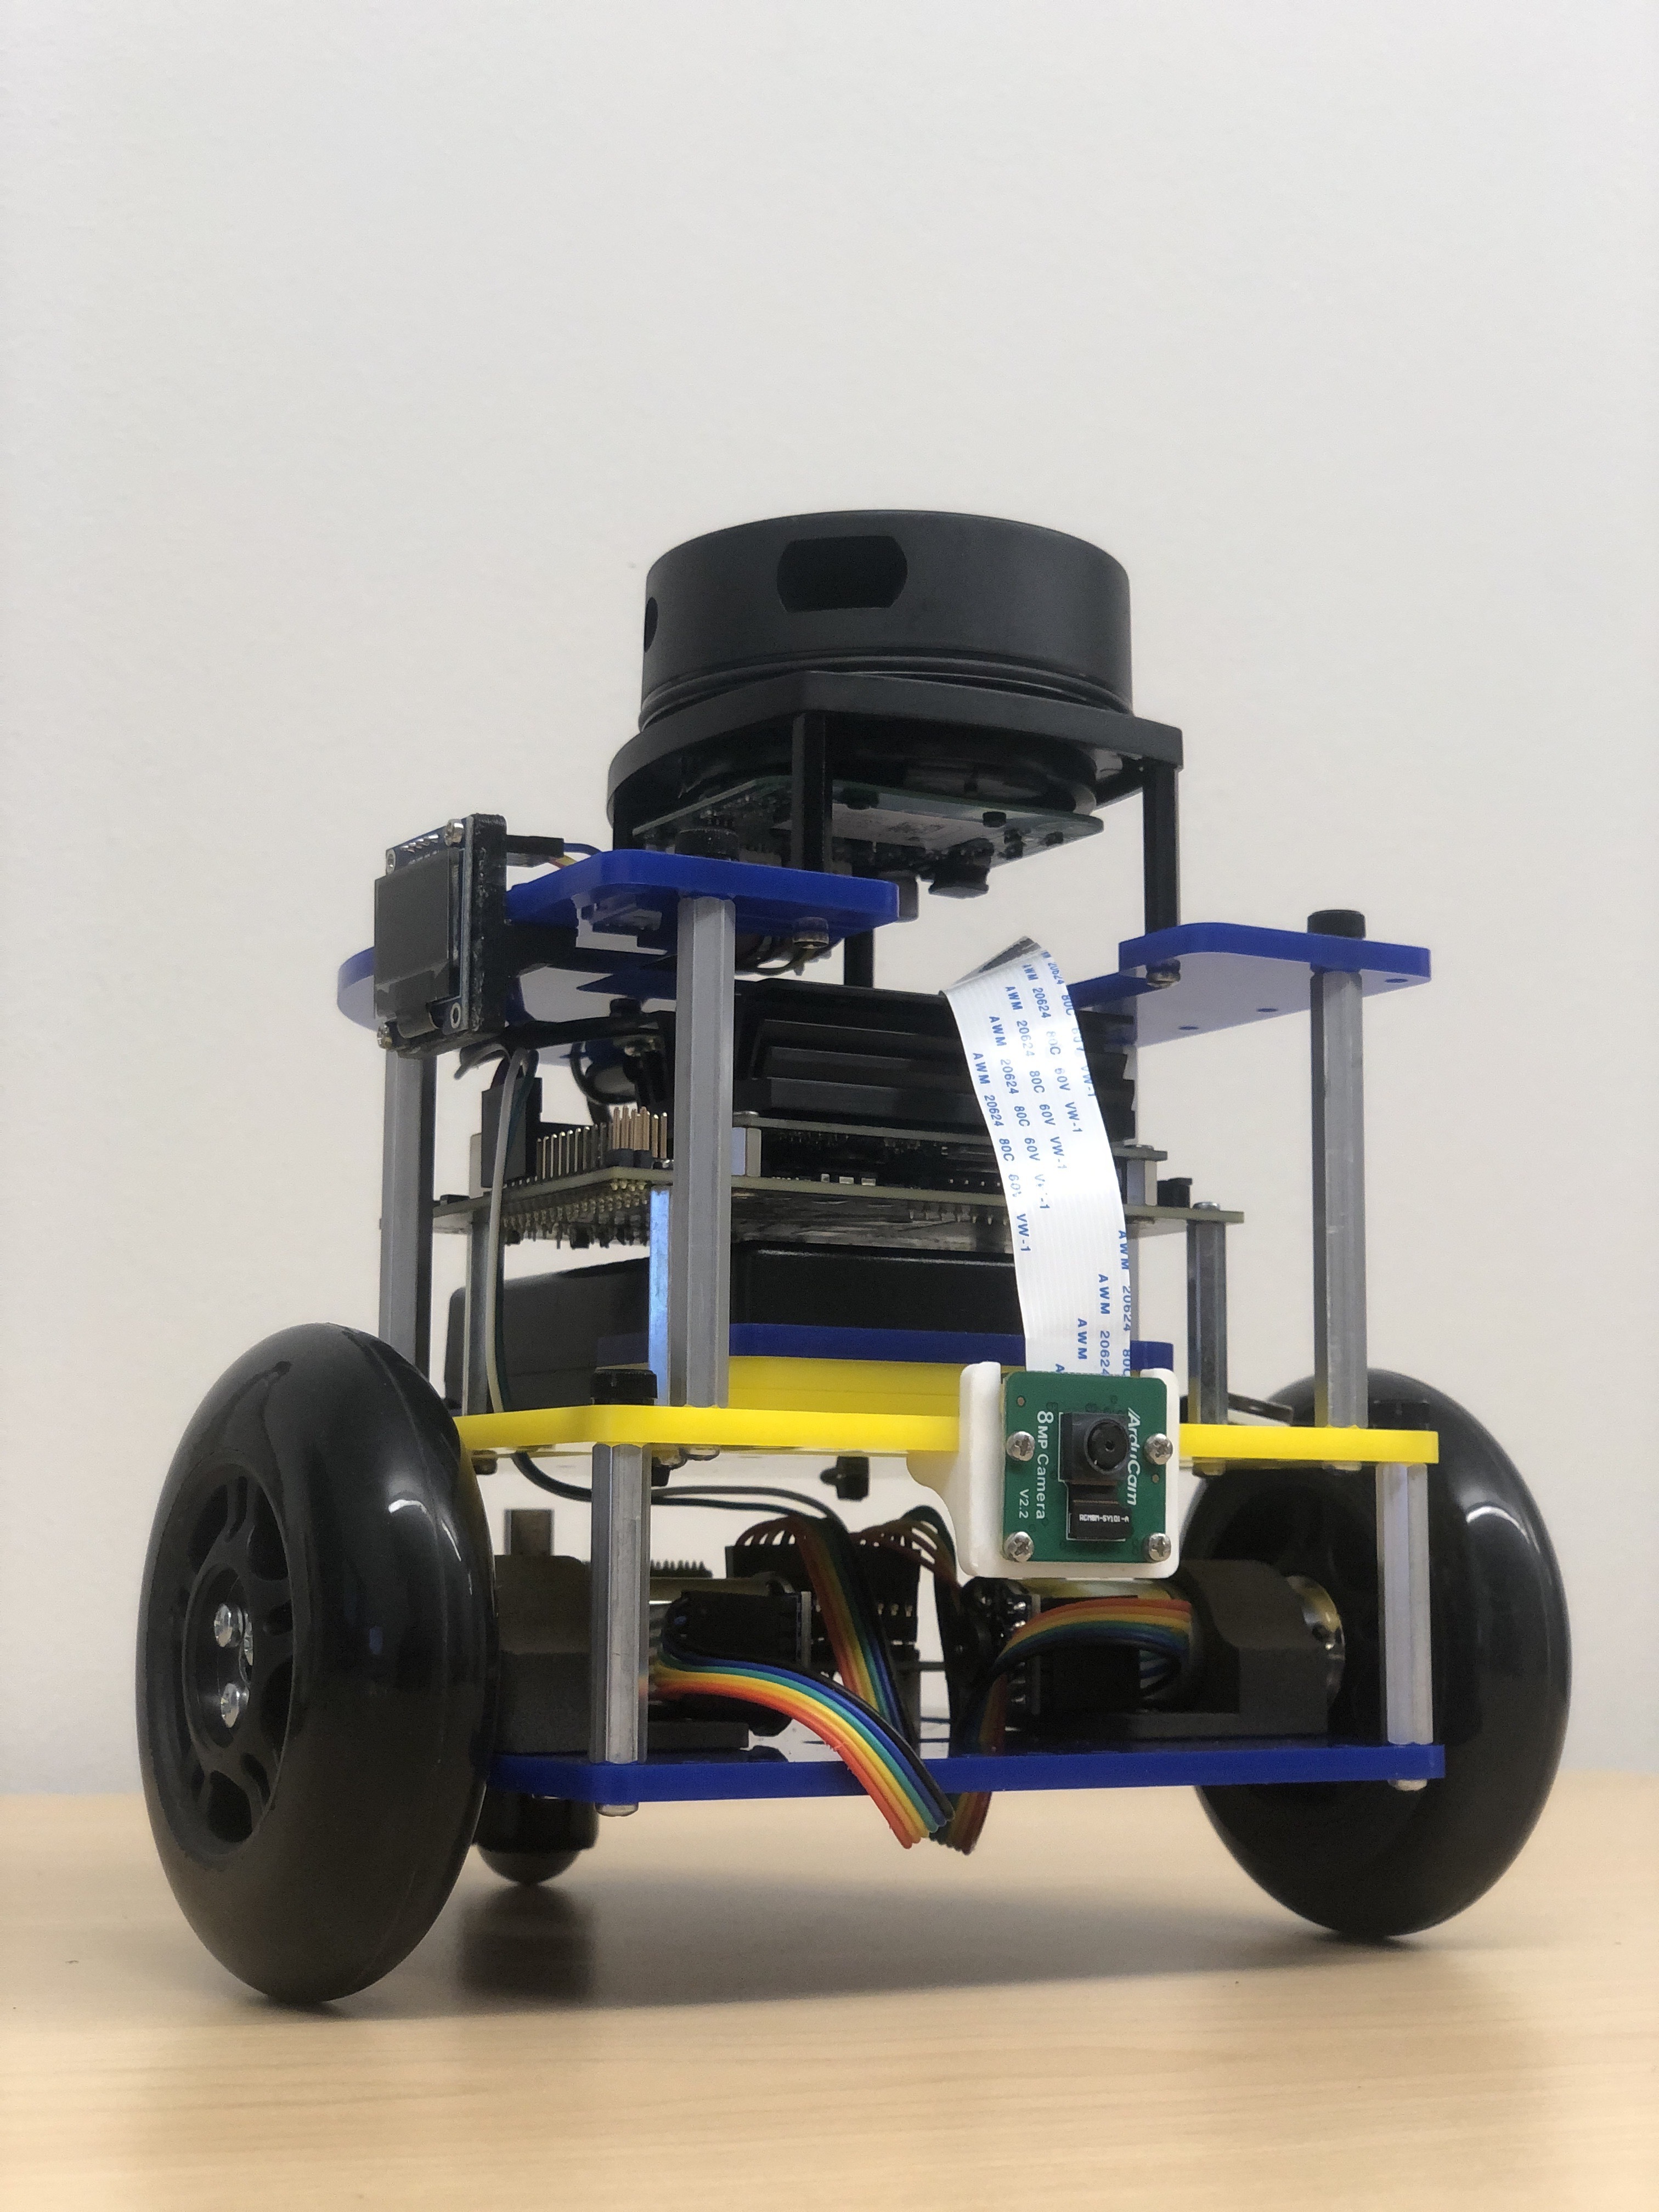
This guide is for Differential Drive MBot Classic final wiring assembly. At the end of this guide, you should have a fully assembled mbot that looks like this:
1. Assemble 3 plates
| Components | # |
|---|---|
| OLED cable | 1 |
| 4-40 thumb screw 3/8” | 8 |
-
Use the thumb screws to attach the middle plate to the bottom plate and secure the screws to the standoffs.
-
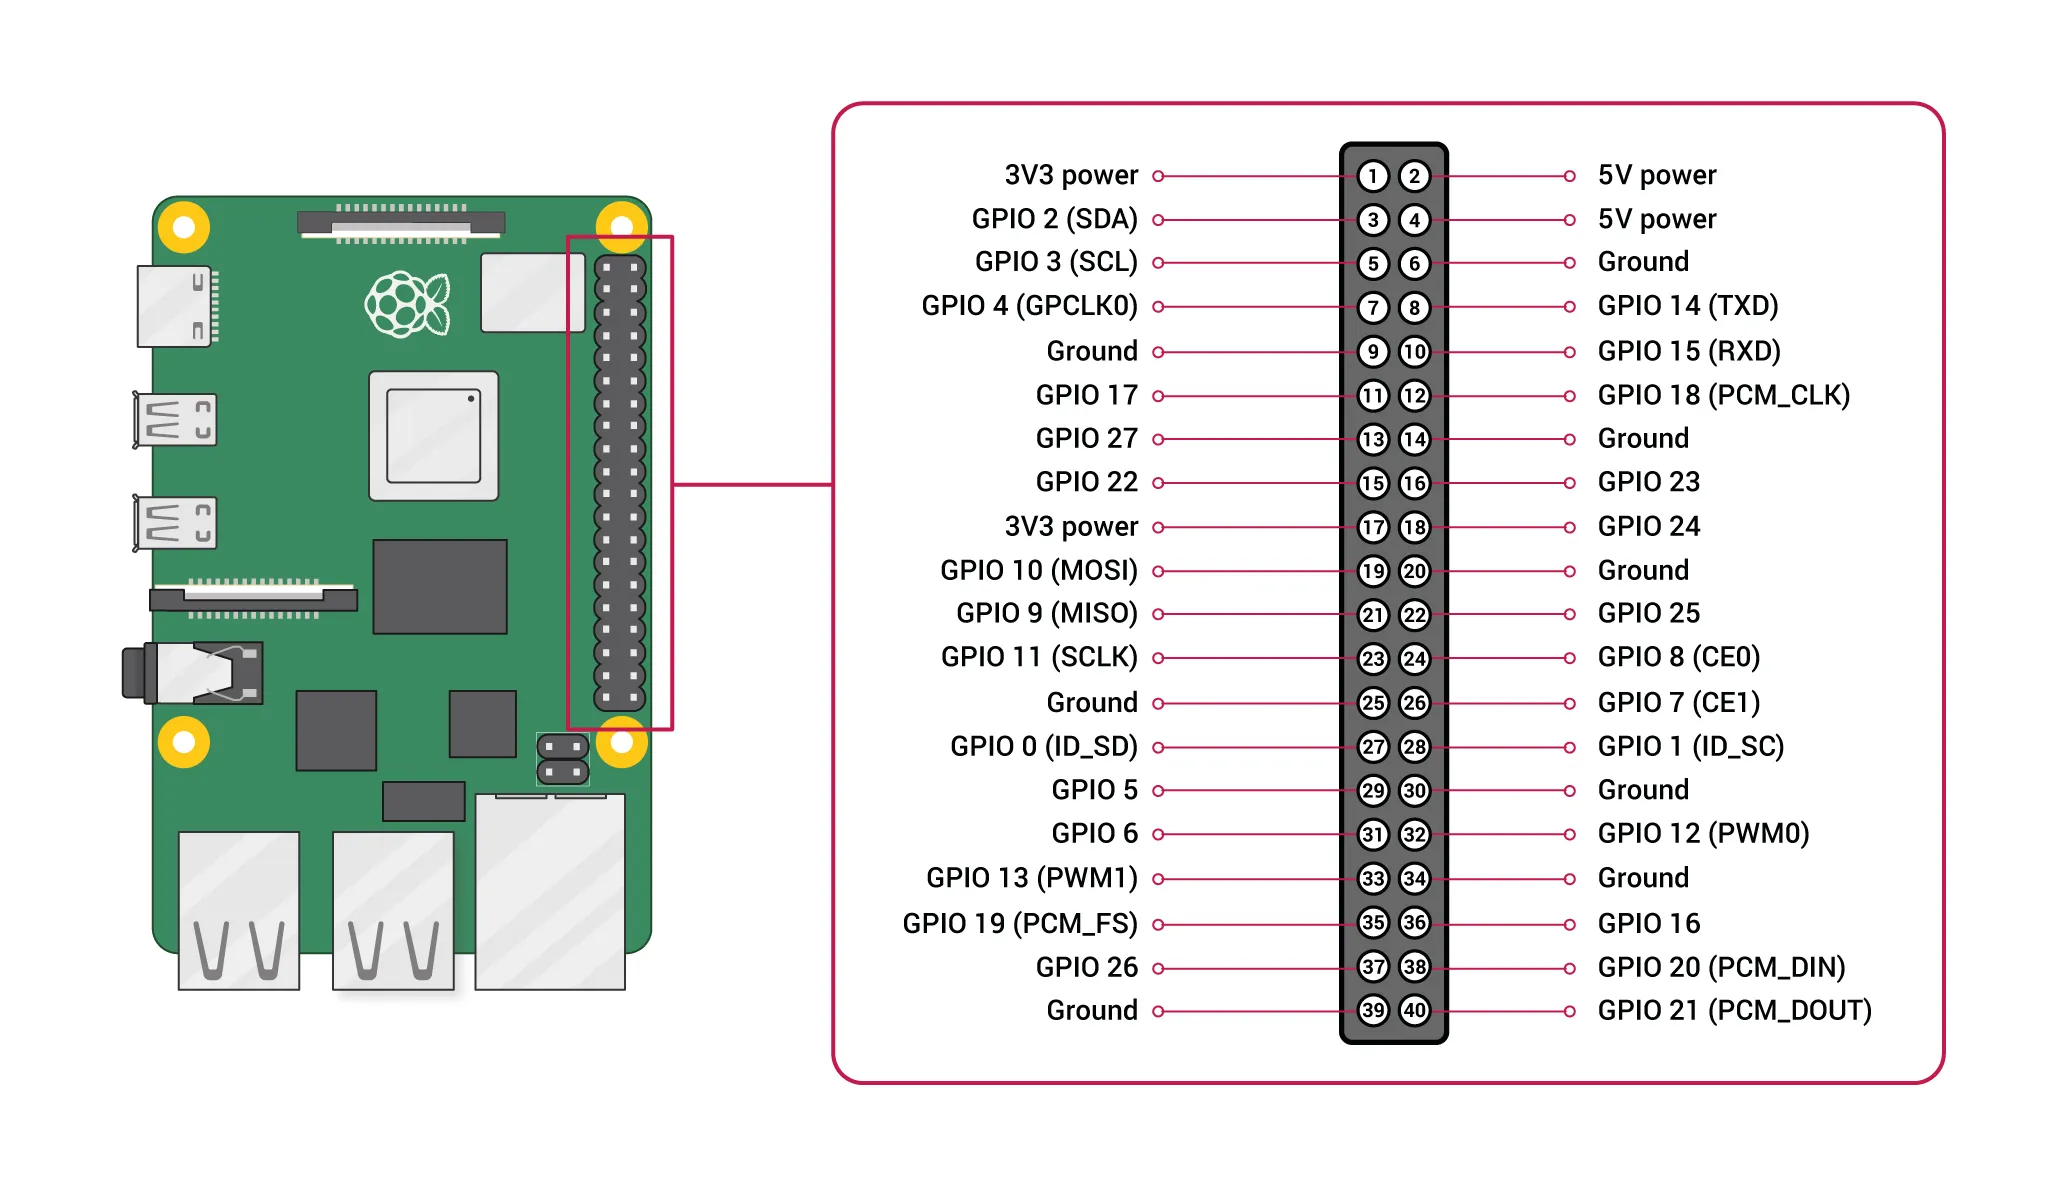
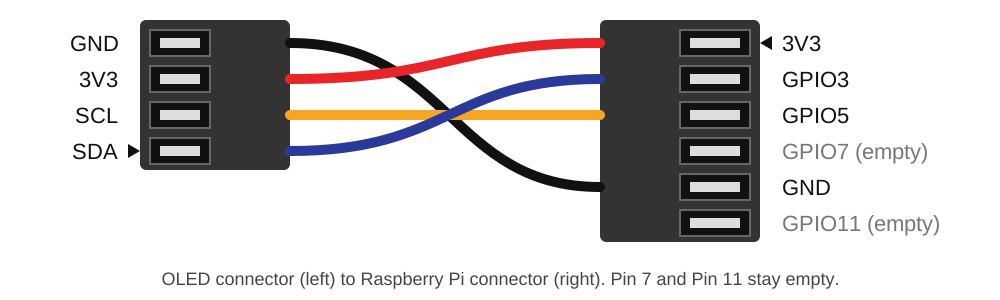
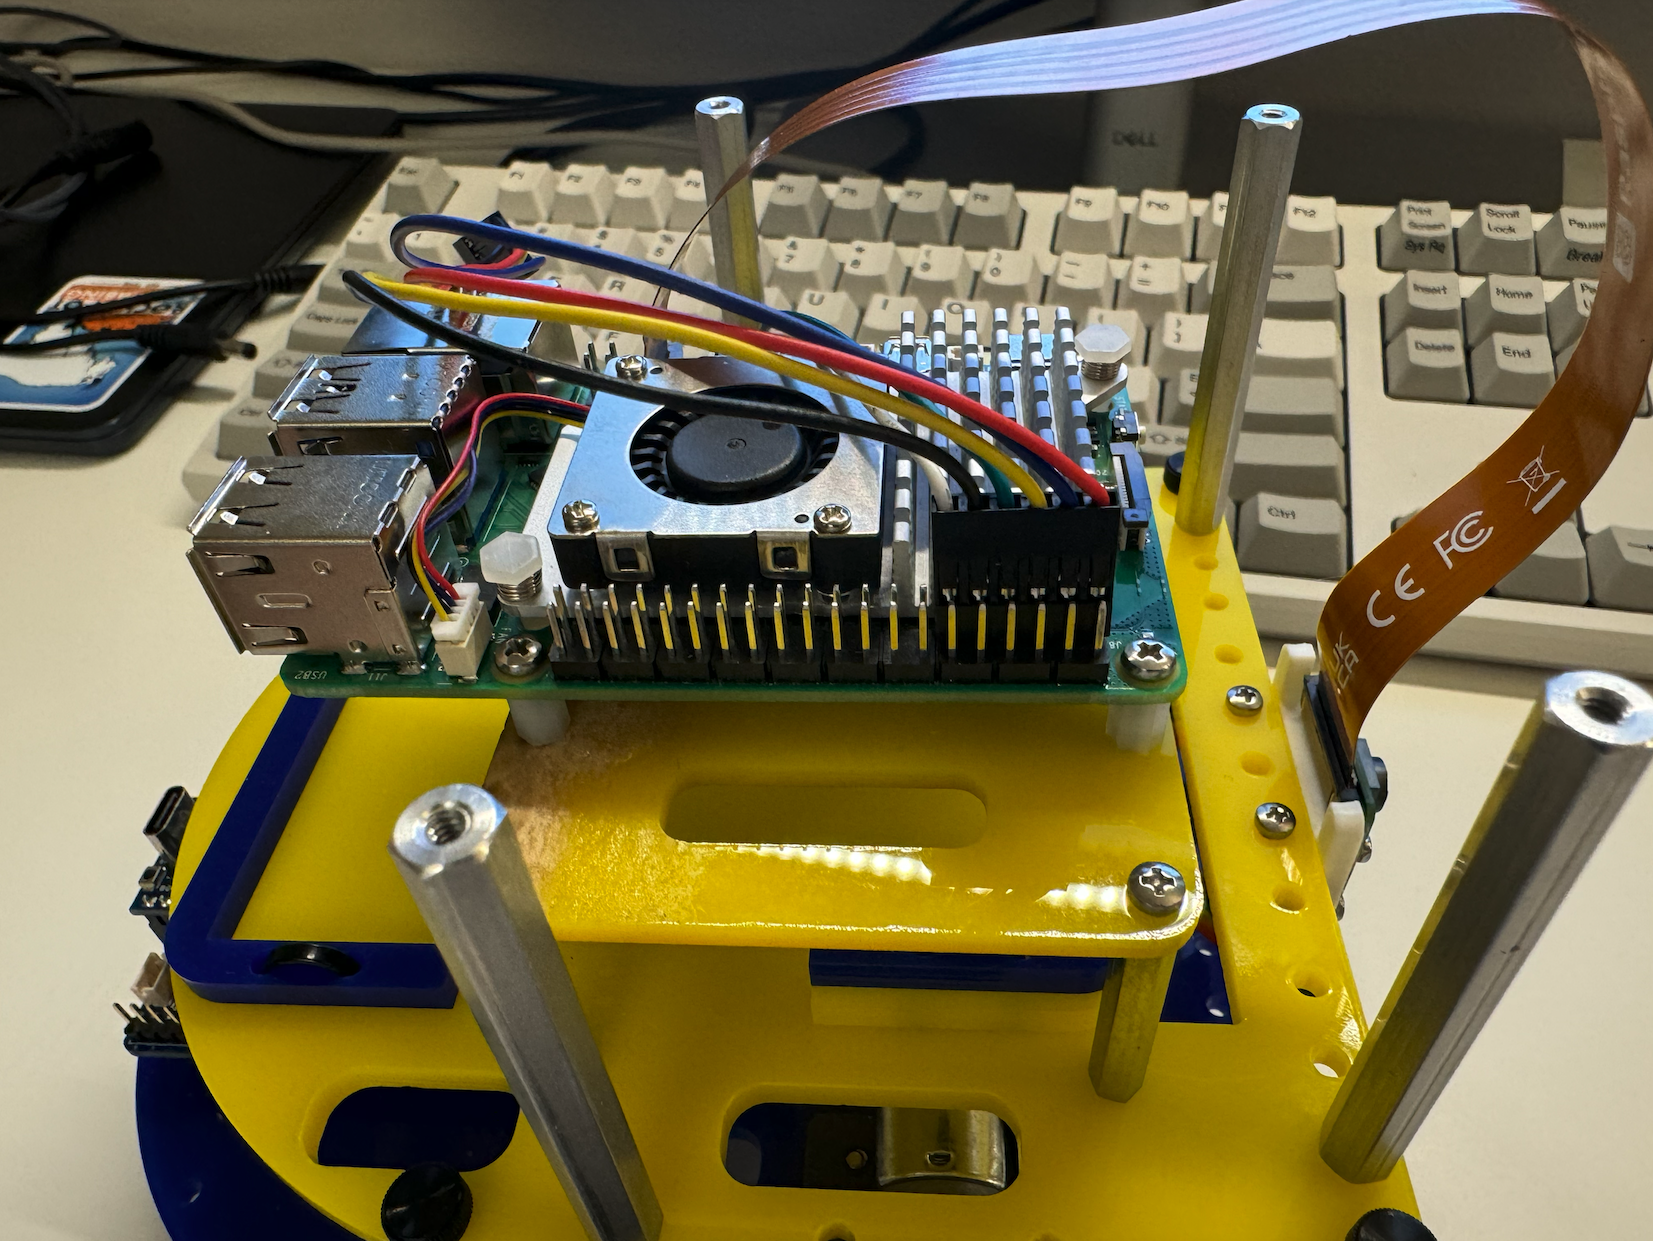
Plug the 6-pin connector of the OLED cable into the Raspberry Pi pins.
According to the image below, the red cable should be connected to Pin 1 (the number inside the circle, not the number marked on the side). Pin 7 and Pin 11 stay empty.
-
Connect the 4PIN connector to the OLED, ensuring that the pins align with the marked positions.

Then, use the thumb screws to attach the top plate to the middle plate and secure the screws to the standoffs.
2. Final Wiring
| Components | # |
|---|---|
| 12V Power Bank | 1 |
| DC power “Y” cable with rounded ends | 1 |
| USB-C Cable | 2 |
- “Y” Shape Power Cable: Connect one barrel plug to the control board and the other to the battery. This powers the control board.
-
USB-C Cable: Plug the Type A end into the battery and the Type C end into the power supply slot on the side of the Raspberry Pi 5. This connection powers the Raspberry Pi.
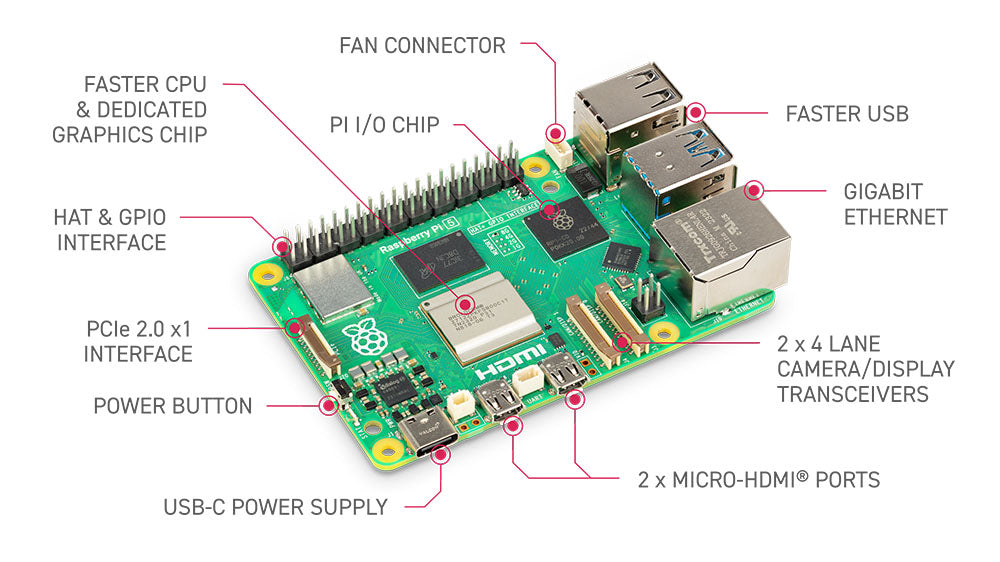
- USB-C Cable: Plug the Type A end into one of the Raspberry Pi’s USB ports and the Type C end into the PICO on the bottom board. This connection enables communication between the Raspberry Pi and the Robotics Control Board.
- Lidar’s USB: Connect the Lidar’s USB cable to one of the Raspberry Pi’s USB ports.
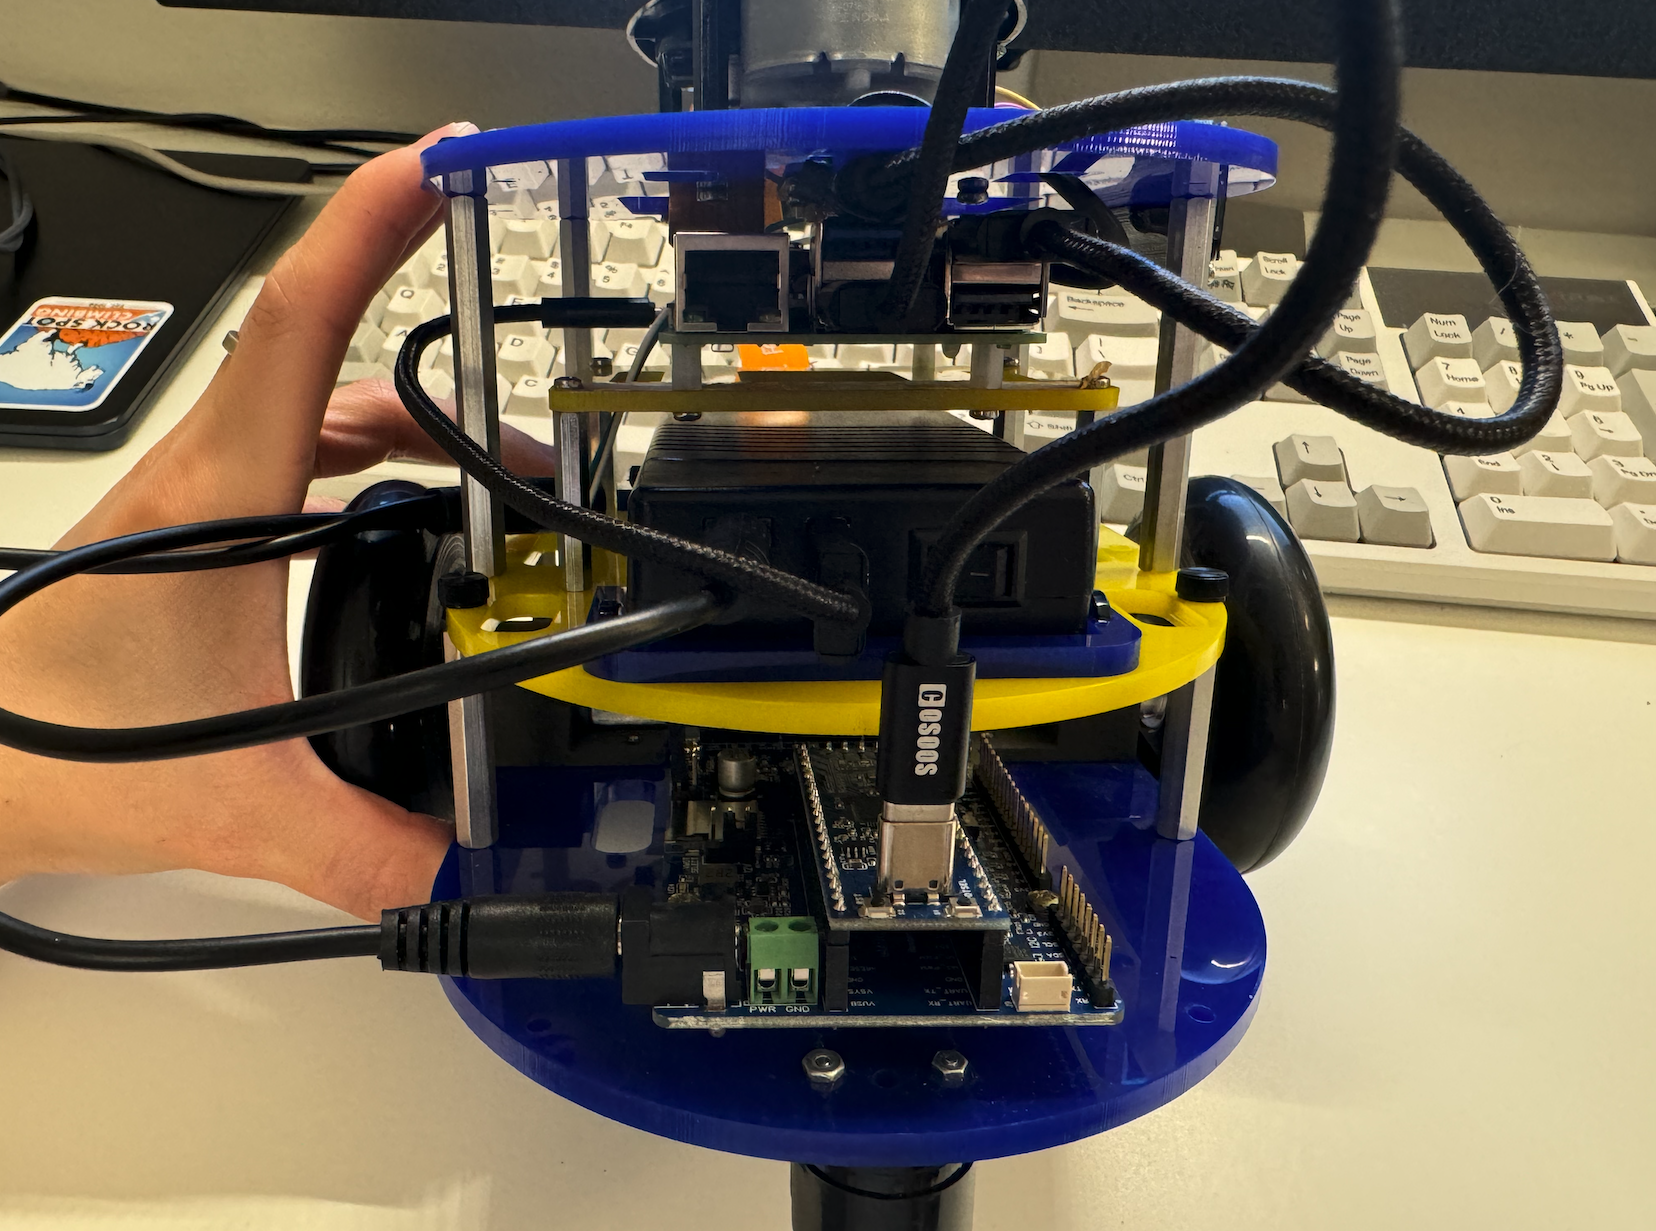
The final result should look like this:
Now you have a complete version of MBot. You are ready to set up the software and make the robot move!